Boston Dynamics
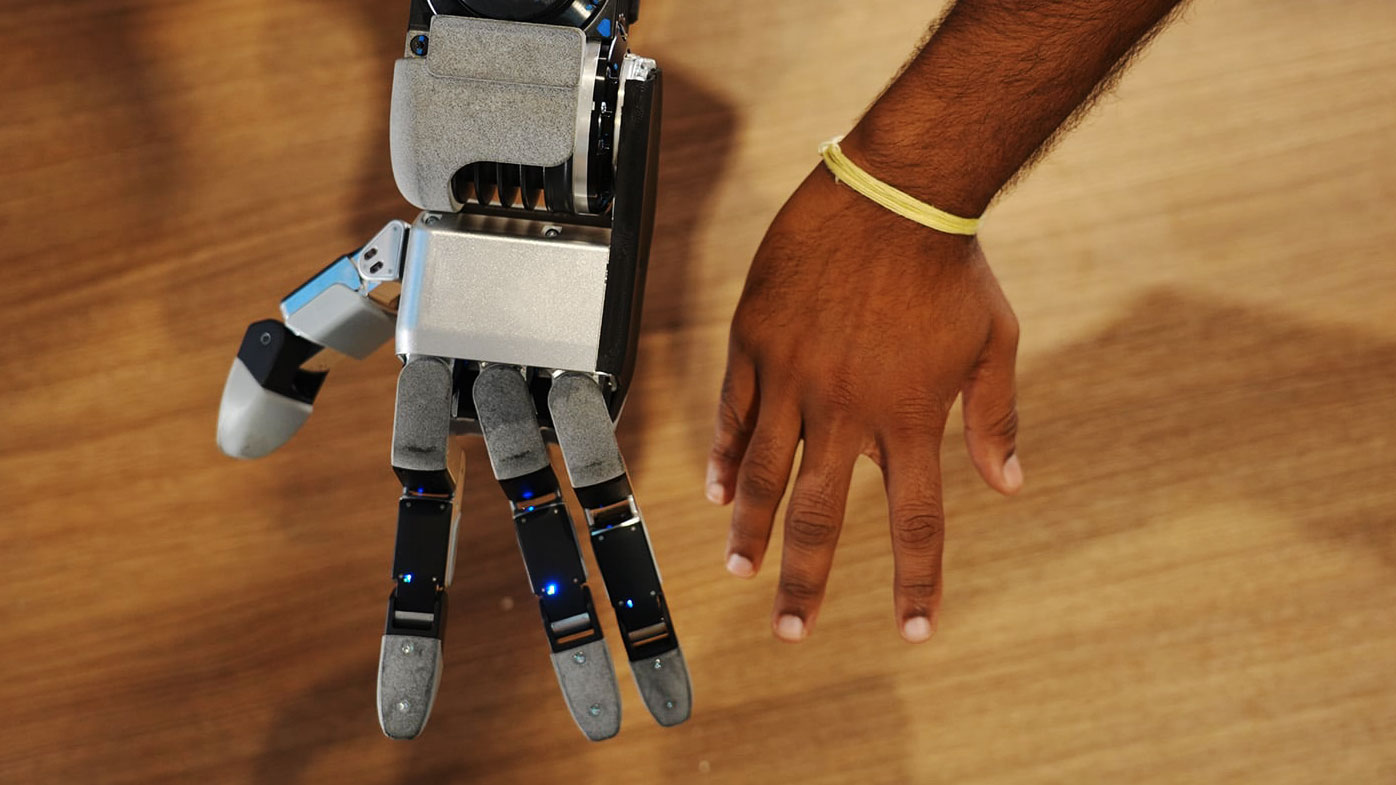
Boston Dynamics' Atlas humanoid robot has new hands, featuring 13 DoF, almost double compared to its previous iteration.
Get news, papers, media and research delivered. Sign up for our free newsletters.
Stay up-to-date with news and resources you need to do your job. Research industry trends, compare companies and get weekly market intelligence with Robotics 24/7.
Boston Dynamics
Boston Dynamics' Atlas humanoid robot has new hands, featuring 13 DoF, almost double compared to its previous iteration.
Boston Dynamics announced a new-generation hand for its Atlas humanoid robot, featuring 13 degrees of freedom (DOF), that is directly actuated, built for high-fidelity simulation to enable sim-to-real RL, and designed from the ground up for dexterous physical work.
The company said that it is a companion to the new generation of Atlas, an agile humanoid robot with a 100lb+ payload and the simplicity necessary for mass manufacturing.
In the sprint to build humanoid robots, Boston Dynamics said that the common industry choice is to equip a humanoid with a close replica of a human hand. The company said that there is an intuitive logic to it:
The company said that making a useful humanoid hand, however, is about much more than theoretical capability. In practice, Boston Dynamics said that hand design is a ruthless trade-off.
Dexterity, strength, ruggedness, cost, repairability and sensing all compete with each other. The company said that the real challenge is in designing a hand that:
Boston Dynamics said that this new-generation Atlas hand is their answer for that trade-off.
Boston Dynamics said that Atlas’ previous seven DOF hands were designed to grasp a large variety of objects, whereas this new generation is designed to manipulate them. The company said that it has moved to four fingers, including a more dexterous thumb, with a total of 13 DOFs, maintaining highly transparent direct actuation at the joints, all with a single actuator type. As in Atlas’ body, Boston Dynamics said that these actuators are completely encapsulated, with no fragile cables crossing joints.
The company said that size is one of the main constraints in the design. Boston Dynamics said that Atlas is meant to use objects and reach into spaces sized for people. The company said that it also wanted a minimal cross-embodiment gap from human manipulation data.
As a result, Boston Dynamics said that the hand is similar in size to a large human hand, which heavily drives the size of the actuators. Thanks to several unique actuation technologies, Boston Dynamics said that it maintained similar strength to the previous hand - capable of carrying a 100lb+ loaded minifridge.
The company said that the new hand optimizes the kinematics for in-hand dexterity. Boston Dynamics said that the four-DOF opposable thumb has a much more anthropomorphic configuration, and all other fingers have three DOFs configured to allow finger splaying and full control of their fingertips. The company said that this gives Atlas a leap in dexterous hand behaviors, now capable of:
Click here to learn more about Atlas’ new hand, including why Boston Dynamics chose not to add a fifth finger to the design.
Enjoyed this article? Add Robotics 24/7 as a preferred source in Google Search.
Edge computing gives AI agents the processing power to turn instructions into…
President Trump orders a review of robotics imports over national security…
Platform helps robots adapt to complex tasks
Look beyond the headlines for the latest in humanoid robots