InOrbit.AI
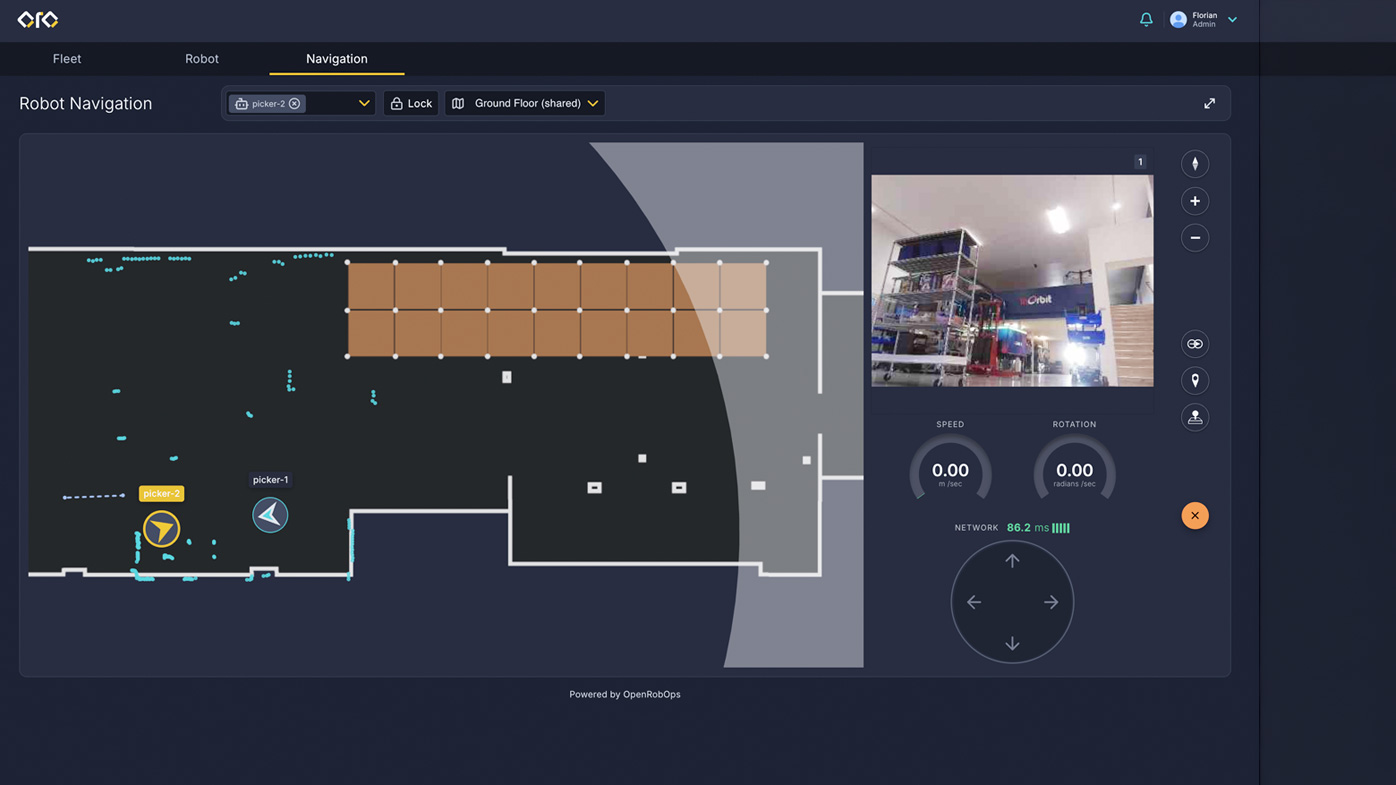
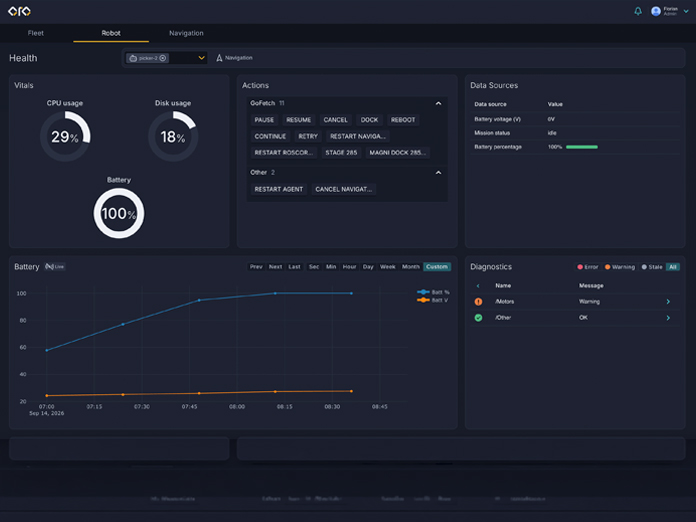
InOrbit.AI released OpenRobOps (ORO), a full, open-source fleet manager for robotics developers who want to complement their robots with a robot operations layer.
Get news, papers, media and research delivered. Sign up for our free newsletters.
Stay up-to-date with news and resources you need to do your job. Research industry trends, compare companies and get weekly market intelligence with Robotics 24/7.
InOrbit.AI
InOrbit.AI released OpenRobOps (ORO), a full, open-source fleet manager for robotics developers who want to complement their robots with a robot operations layer.
InOrbit.AI announced the release of OpenRobOps (ORO), an open-source robot operations and fleet management software designed to support scaled deployments.
The company said that the release delivers a complete operations layer that allows robot builders to deliver a robust fleet manager out of the box, and includes the world's first reference implementation of the ISO 21423 standard.
As the robotics industry rapidly expands, InOrbit.AI said that as the industry attracts more original equipment manufacturers (OEMs), their customers expect them to provide full-featured fleet managers with common functionality. The company said that many OEMs fall into the 'build trap,' spending years developing and maintaining custom backends, databases, and user interfaces instead of focusing on their core innovations.
InOrbit.AI said that OpenRobOps (ORO) helps developers escape this trap by providing a production-grade open foundation, allowing them to shift their focus from recreating basic fleet management functionality to building and deploying useful robots.
"Working with leading enterprises in manufacturing, logistics and other industries, I have seen firsthand that federated orchestration is essential to scaling automation," said Florian Pestoni, founder and CEO of InOrbit.AI, who serves as a member of the ISO working group and representative for ANSI, the US national body. "I’m proud of the collaborative work that led to this landmark international interoperability standard. With OpenRobOps, we are helping take this from theory to market practice."
Pestoni is also a member of the Robotics 24/7 Executive Advisory Board.
The company said that OpenRobOps also includes the industry’s first reference implementation of an upcoming interoperability standard from the International Organization for Standardization (ISO). The ISO 21423 specification establishes the communication and data exchange standard for industrial mobile robots (IMRs) and fleet managers (IMRFMs). By providing native ISO 21423 support, InOrbit.AI said that OpenRobOps enables OEMs to easily build solutions leveraging the new standard.
At Automate 2026, 10 different companies participated in a demonstration of multi-vendor orchestration based on InOrbit Space Intelligence, InOrbit.AI’s flagship product. The company said this was the first public demonstration of ISO 21423, and OpenRobOps’ release brings the technology powering those demonstrations directly to the open-source robotics community, empowering OEMs to build standard-compliant fleet managers and reduce friction for their customers.
InOrbit.AI said this key contribution to the open-source robotics community mirrors the introduction of the Robot Operating System (ROS), which served as a catalyst for robotics development, saving researchers and engineers countless hours of rewriting low-level code from scratch and bringing together a strong developer community.
"When we created ROS, our mission was to give roboticists an open ecosystem so they could stop re-inventing basic device drivers," said Steve Cousins, executive director of the Stanford Robotics Center, member of the InOrbit.AI Board of Directors, and former CEO of Willow Garage. "OpenRobOps creates the same shift for robot operations and fleet management, while also enabling standards-based interoperability."
By providing a production-grade operations foundation out of the box, InOrbit.AI said that OpenRobOps allows teams to bypass years of backend development. The company provided the following key features of OpenRobOps:
InOrbit.AI added that OpenRobOps is distributed under the permissive Apache 2.0 license, allowing academic researchers, robotics startups and commercial enterprises to adapt, embed and deploy the software without licensing fees.
Enjoyed this article? Add Robotics 24/7 as a preferred source in Google Search.
Edge computing gives AI agents the processing power to turn instructions into…
President Trump orders a review of robotics imports over national security…
Platform helps robots adapt to complex tasks
Look beyond the headlines for the latest in humanoid robots